Yared Legese
Hi, I'm Yared Legese.
I'm a Mechanical Engineer passionate about designing, analyzing, and improving real-world engineering systems. My experience spans autonomous mining systems, off-grid energy solutions, Formula SAE powertrain and suspension design, and HVAC and medical gas systems.
Experience
May 2026 - Aug 2026
Nevada Gold Mines | Mechanical Engineering Intern
Autonomous boom-gate access control and off-grid power
Cut inverter standby current from 2.3 A to 1.7 A (about 26%) through AES-mode configuration, saving about 184 Wh per day.
Reviewed solar and battery performance, including cycles per charge, battery life, and seasonal derating, and identified a low-temperature threshold affecting the battery self-heating circuit.
Prepared the I/O list, sequence of operation, and cause-and-effect matrix for gate operation, vehicle detection, and obstruction detection.
Jan 2023 - Jan 2024
Getamesay Electromechanical Contractor | Electromechanical Engineer
Hospital HVAC and medical gas piping systems
Improved overall energy efficiency by 18% through load calculations, equipment selection, and ASHRAE standards.
Reduced design errors by 25% and project delivery time by 20% with AutoCAD and SolidWorks layouts and clash detection.
Sized oxygen, vacuum, and compressed-air piping using pressure-drop checks and flow balancing to meet healthcare safety codes.
Projects
Select a project to learn more.
Formula SAE | Powertrain and Suspension
00.
PROJECT DETAILS
Role
Powertrain and suspension team member
Timeline
May 2025 - present
Team
Formula Hardrocker SAE, South Dakota Mines
Tools
MoTeC, Realis, SolidWorks
01.
OVERVIEW
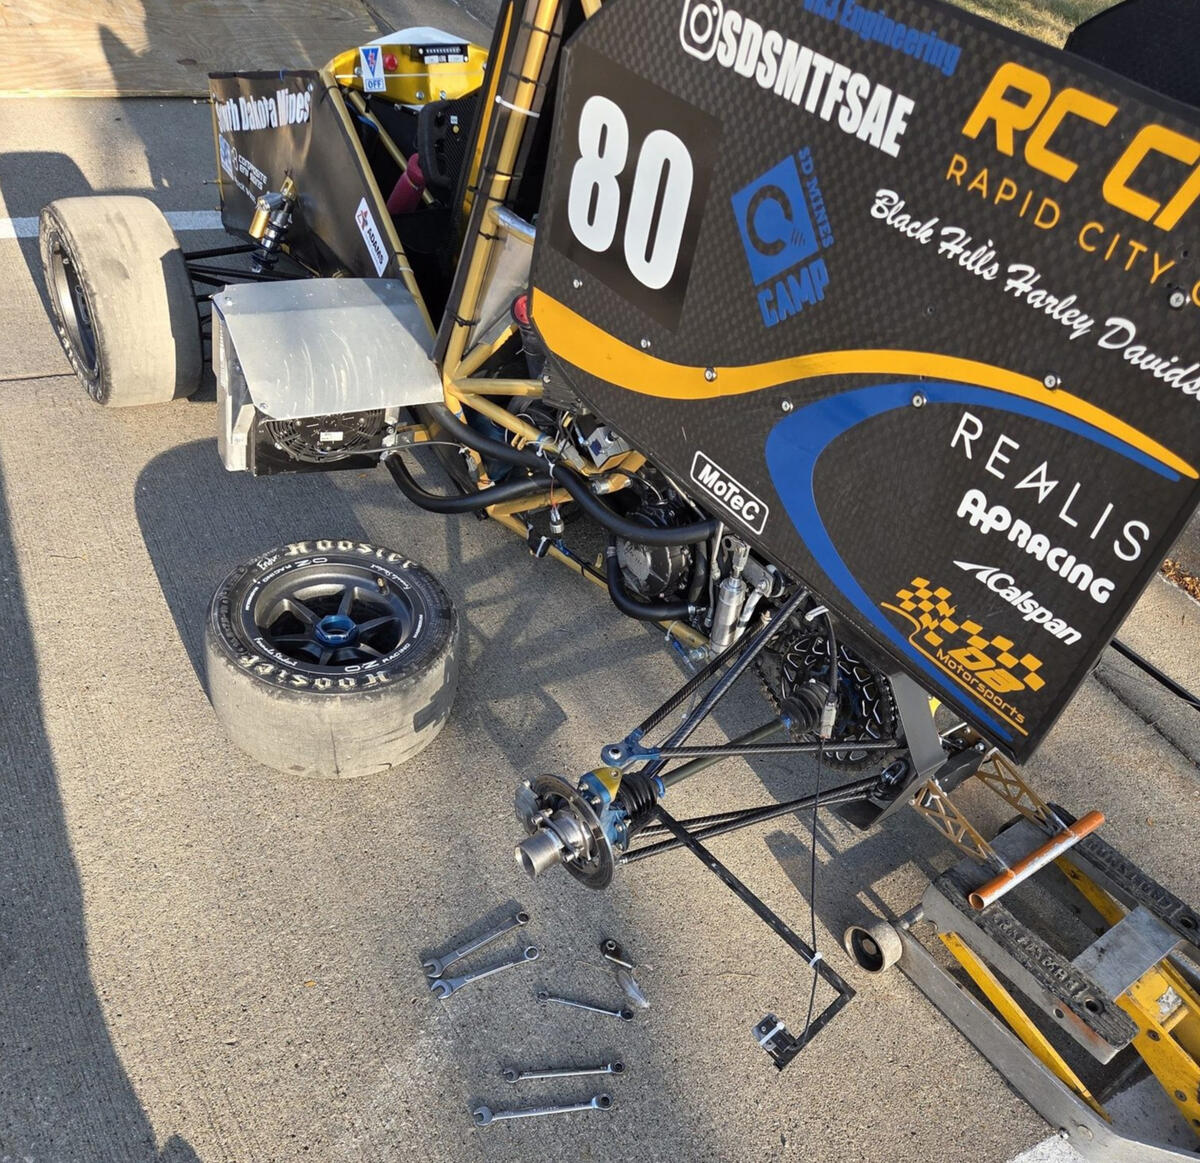
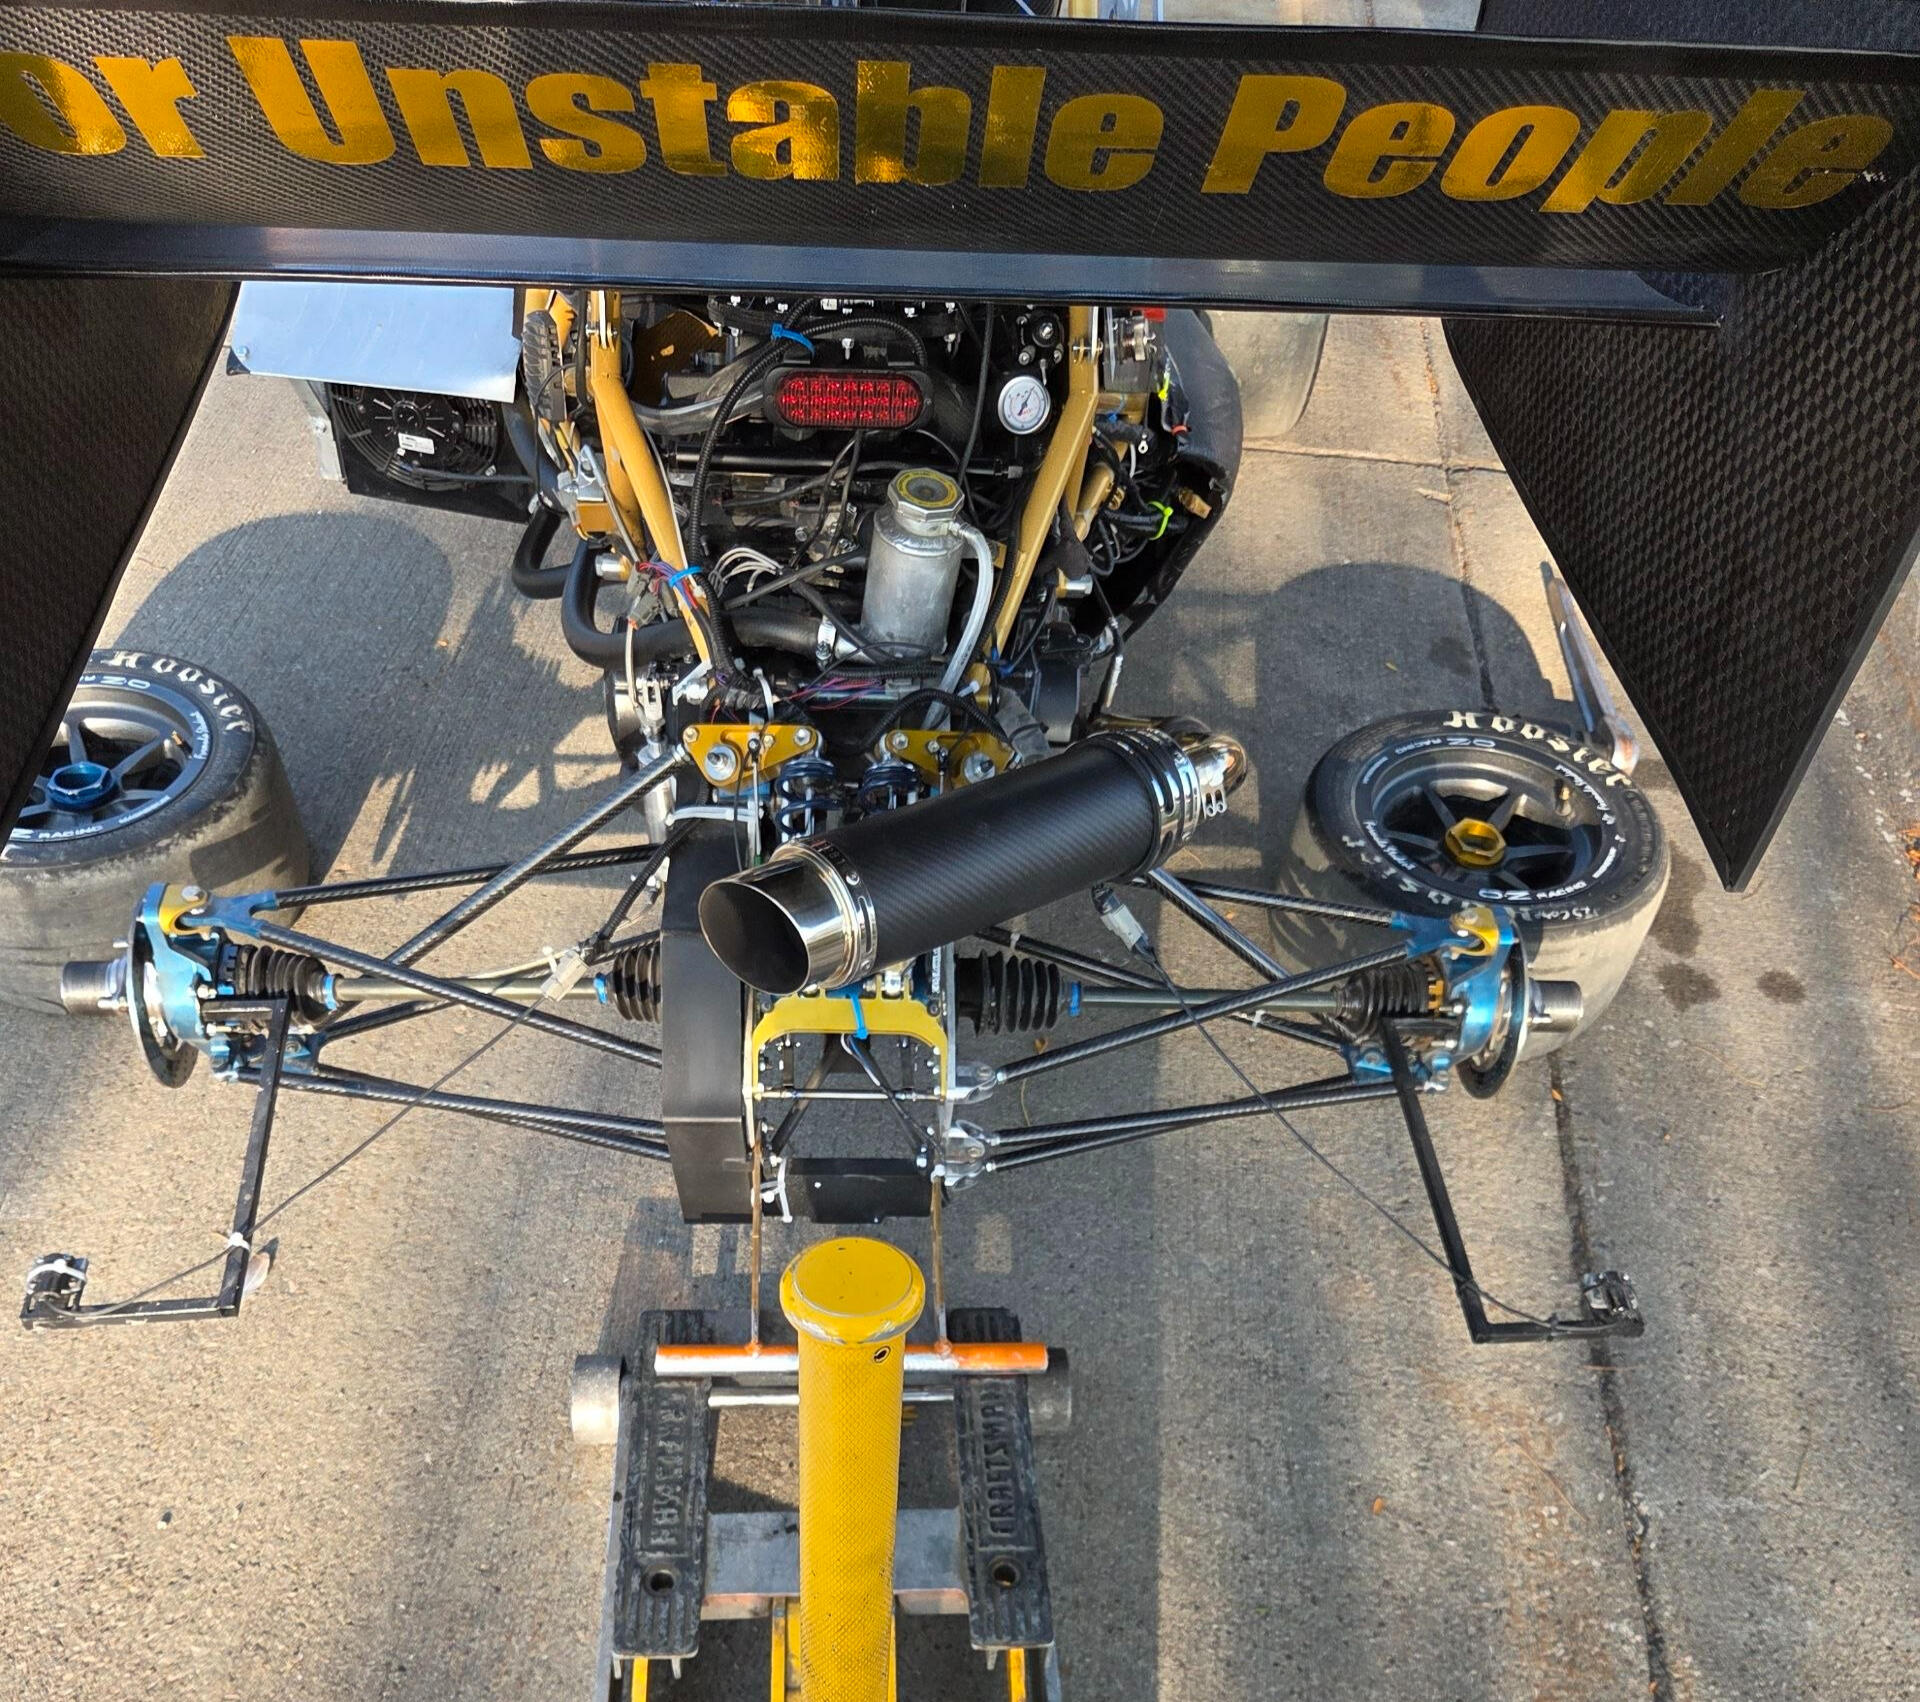
Designing, building, and testing suspension and powertrain subsystems for an open-wheeled race car with the Formula Hardrocker SAE team.
Results
Supported engine calibration in MoTeC (fuel mapping, ignition timing, telemetry analysis), contributing to 12% higher torque and 8% higher thermal efficiency in testing.
Optimized intake and exhaust parameters in Realis simulation, reducing predicted exhaust backpressure by 15%.
Refined suspension geometry and drivetrain integration for handling and drivetrain efficiency.
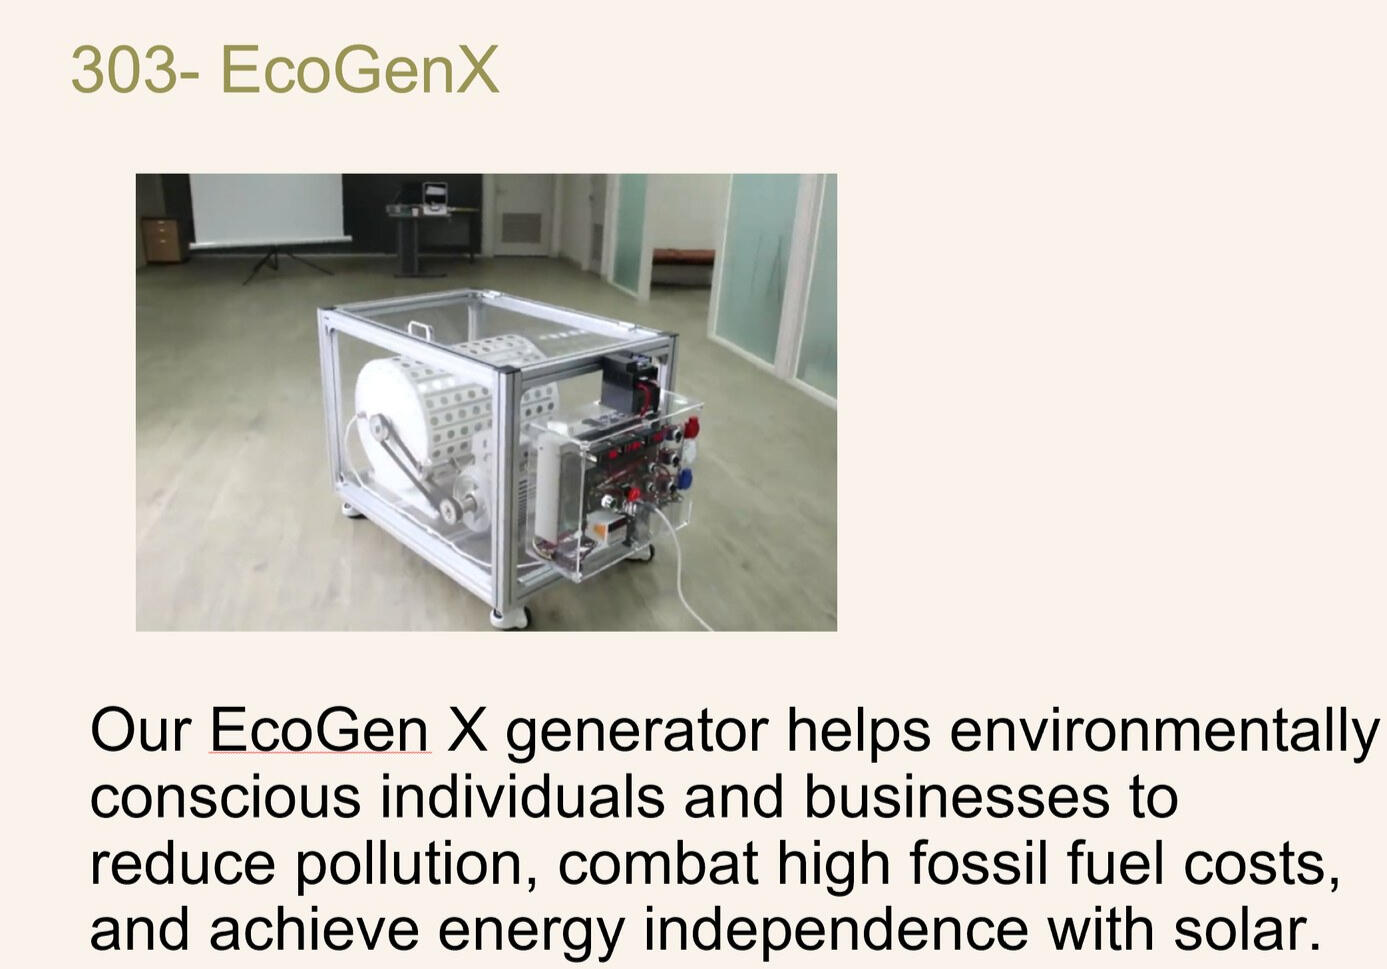
EcoGenX | Technical Lead
00.
PROJECT DETAILS
Role
Technical lead
Timeline
Jan - Aug 2025
Team
5-member student team
Tools
Magnetic flux system design, product architecture, NSF I-Corps customer discovery
01.
OVERVIEW
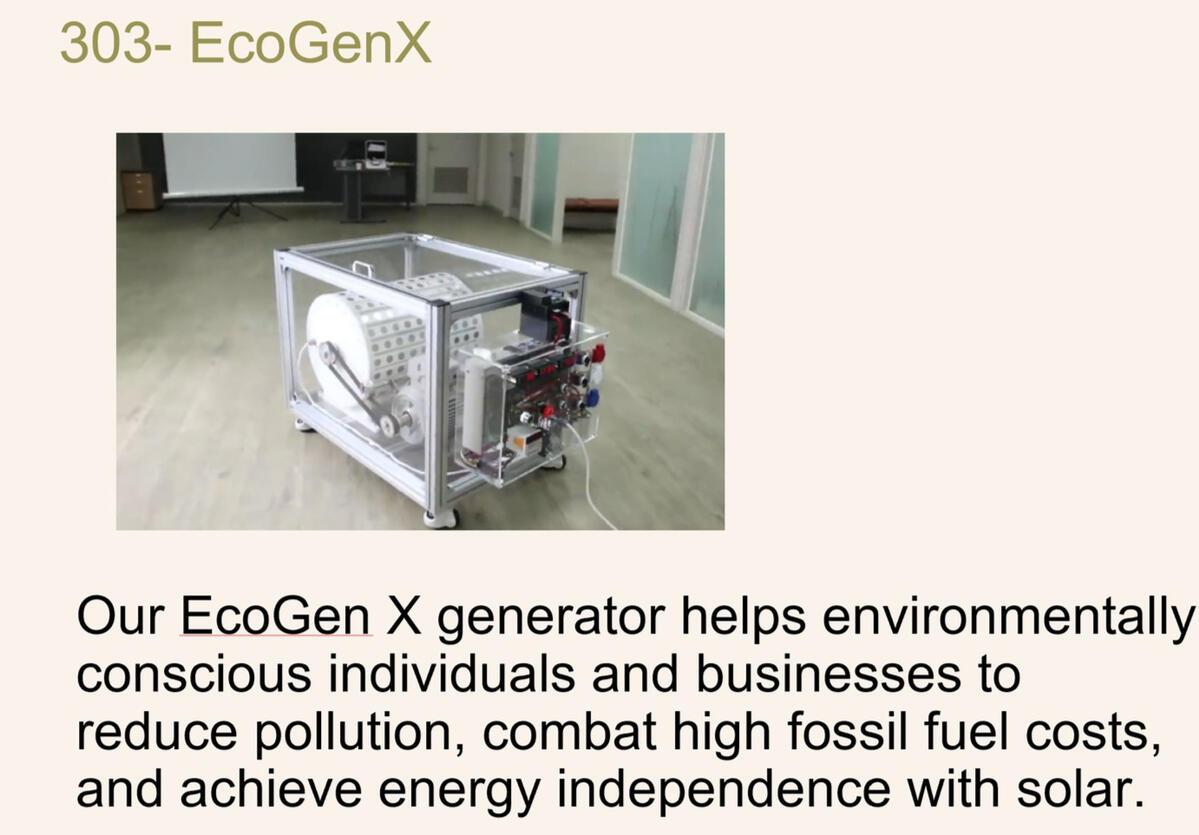
Led development of a 400 W portable fuel-less generator designed as a clean, silent alternative to diesel units, guiding the magnetic flux system design and product architecture.
Results
Coordinated and mentored a 5-member team to a successful MVP demonstration, reducing prototyping time by 30%.
Conducted 60+ customer discovery interviews through NSF I-Corps, validating 70% of key hypotheses.
Placed in the top 20 of the SDM CEO Student Business Plan Competition.
Robotic Control Systems | Graduate Coursework
00.
PROJECT DETAILS
Role
Graduate coursework
Timeline
Jan - May 2025
Team
Graduate course project, South Dakota Mines
Tools
Python, PID control, state-space modeling
01.
OVERVIEW
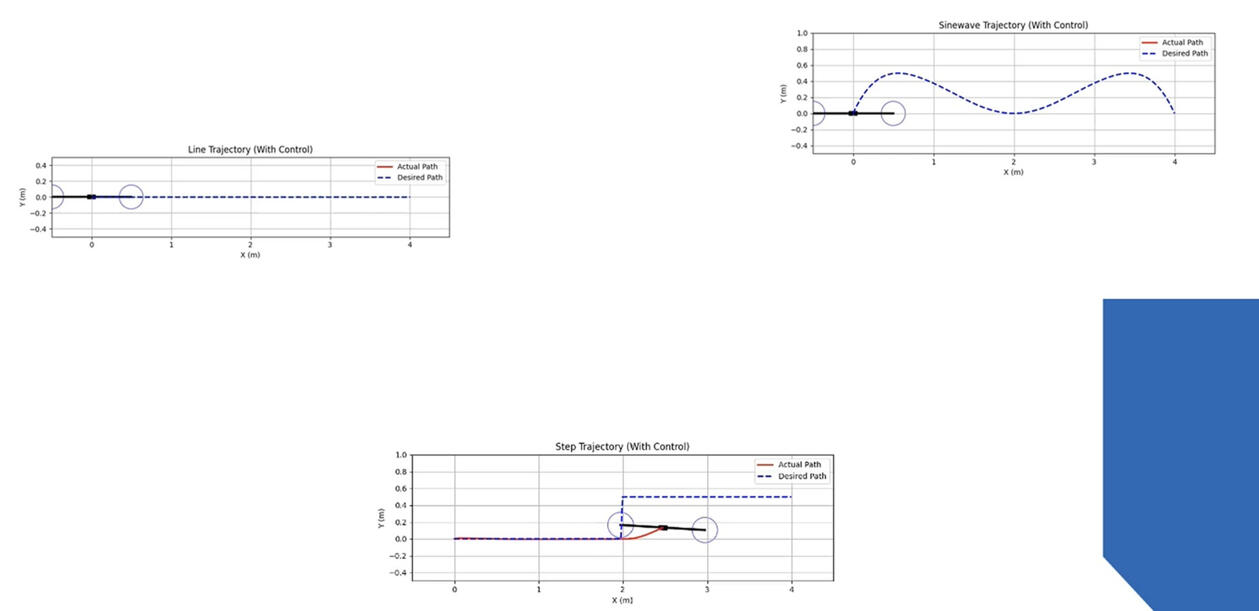
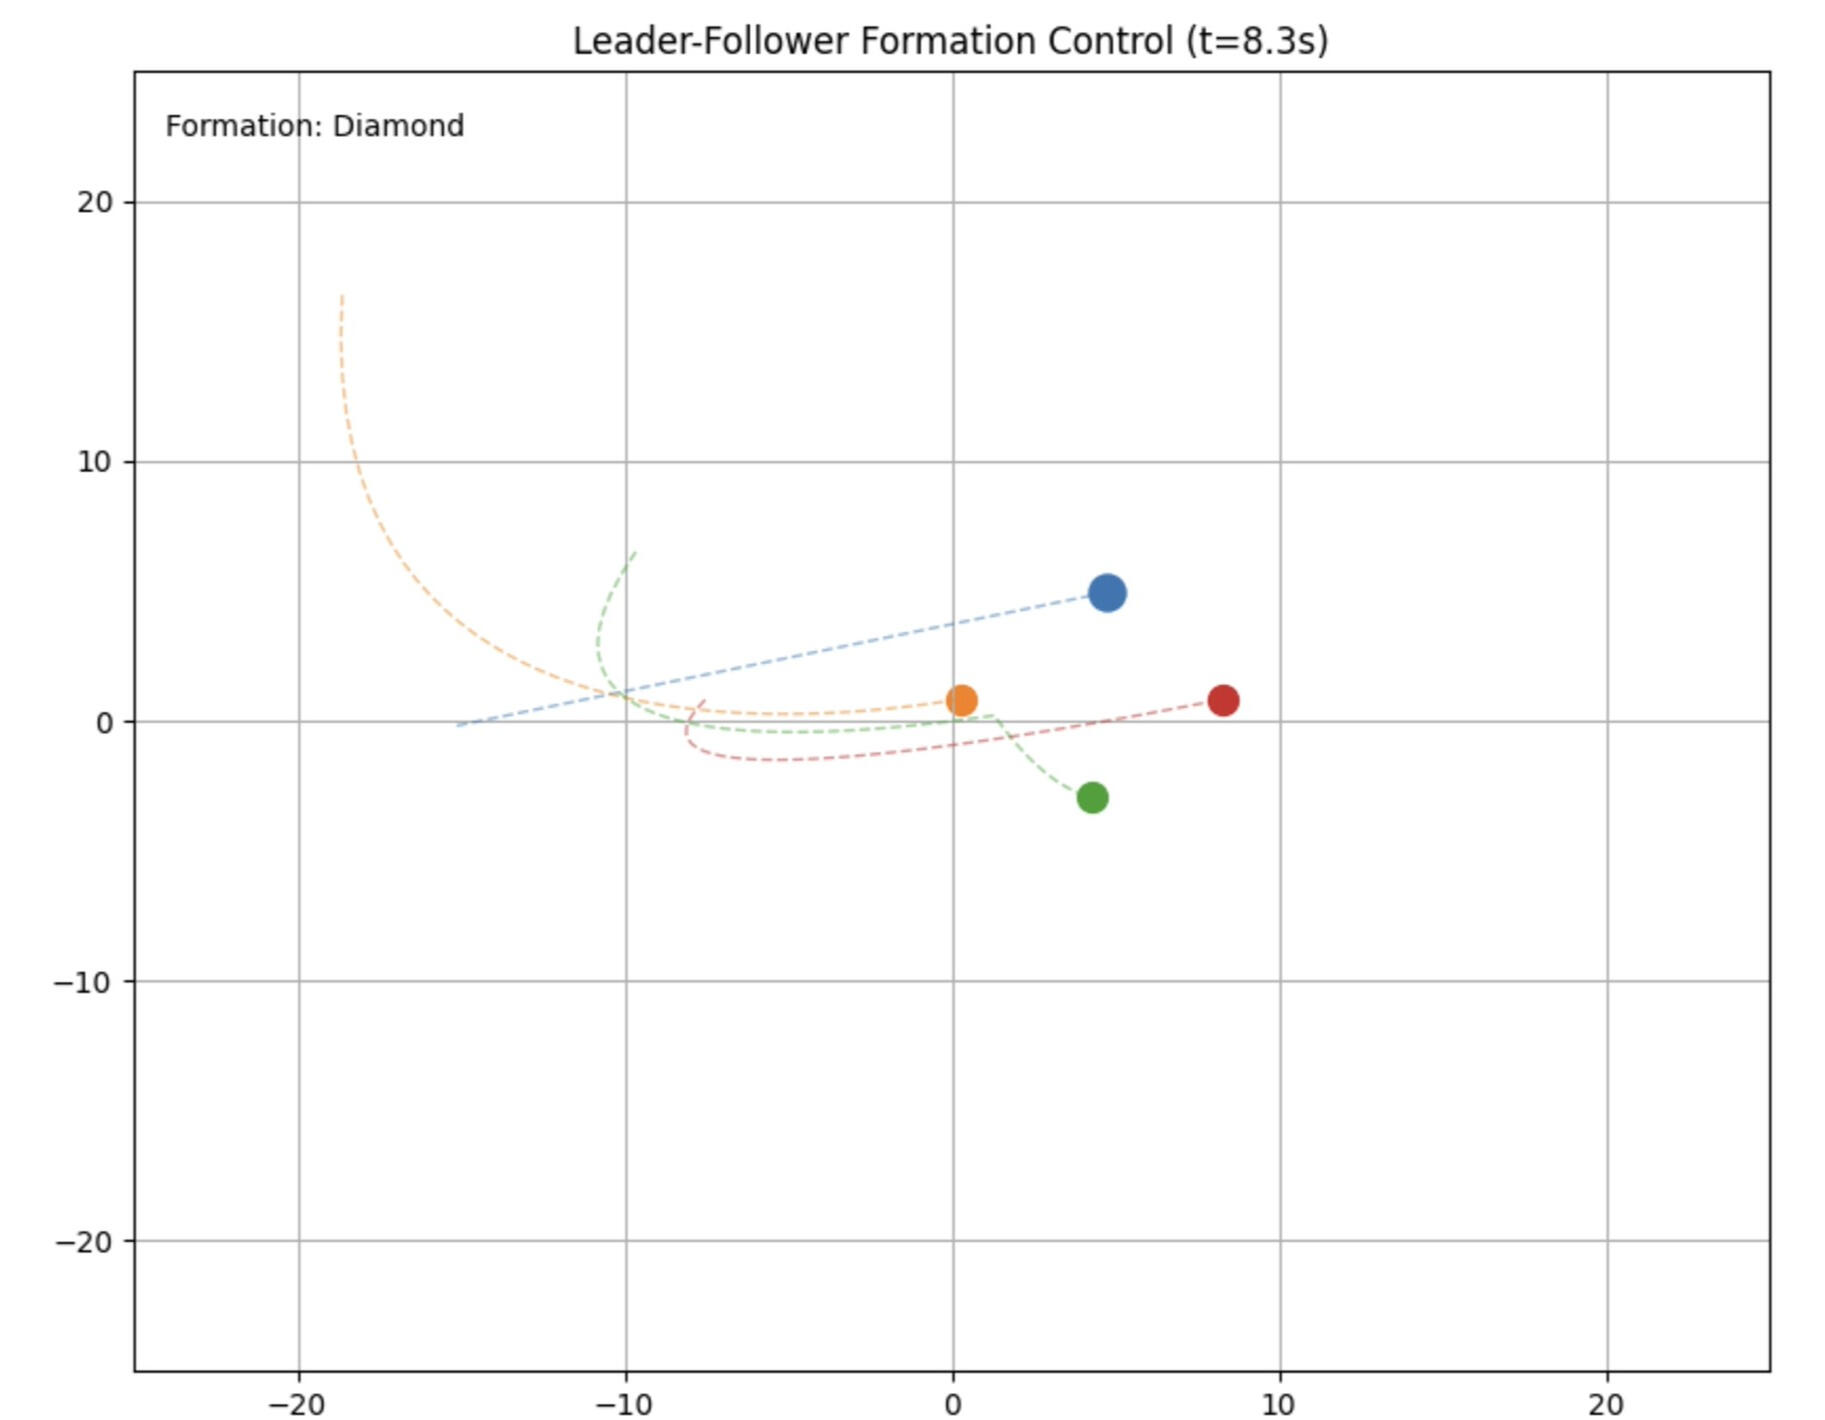
Designed and simulated Python-based PID and state-space controllers to model and stabilize nonlinear and linear systems.
Results
Longitudinal pitch control for a fixed-wing aircraft, with state-space modeling and closed-loop stability analysis.
Altitude and full 3D trajectory tracking for a quadrotor, including hover stabilization and line and sinusoidal paths.
Multi-robot coordination: go-to-goal, breadcrumb path following, moving-target tracking, and consensus rendezvous.
Front Lower Control Arm | Suspension Design
00.
PROJECT DETAILS
Role
Design and 3D modeling
Timeline
2025
Tools
Autodesk Inventor, stress analysis
01.
OVERVIEW
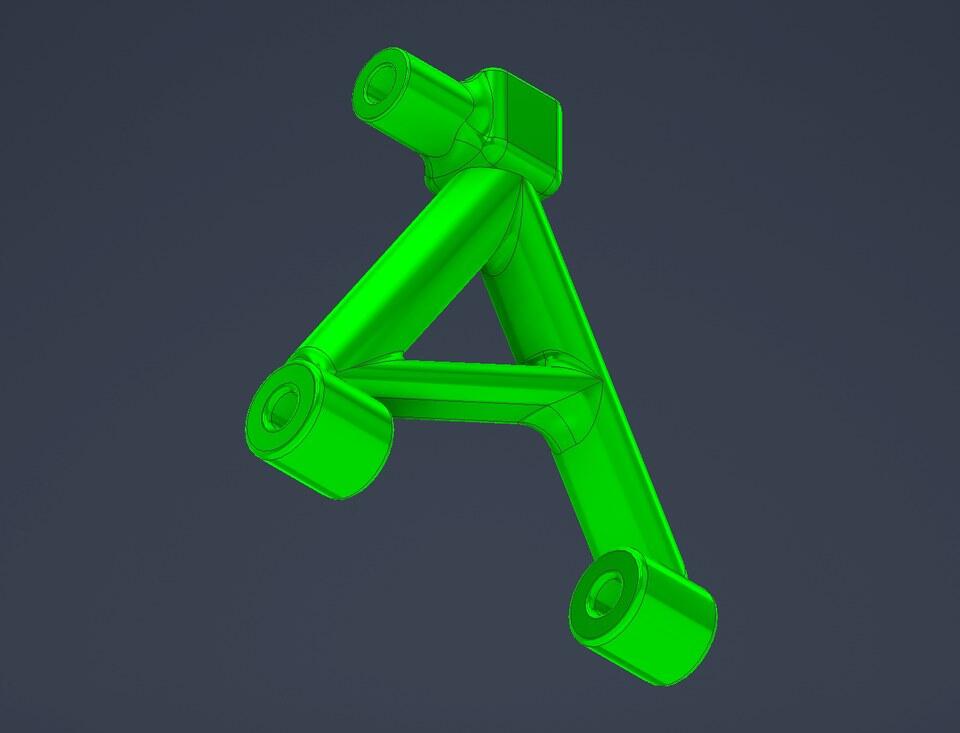
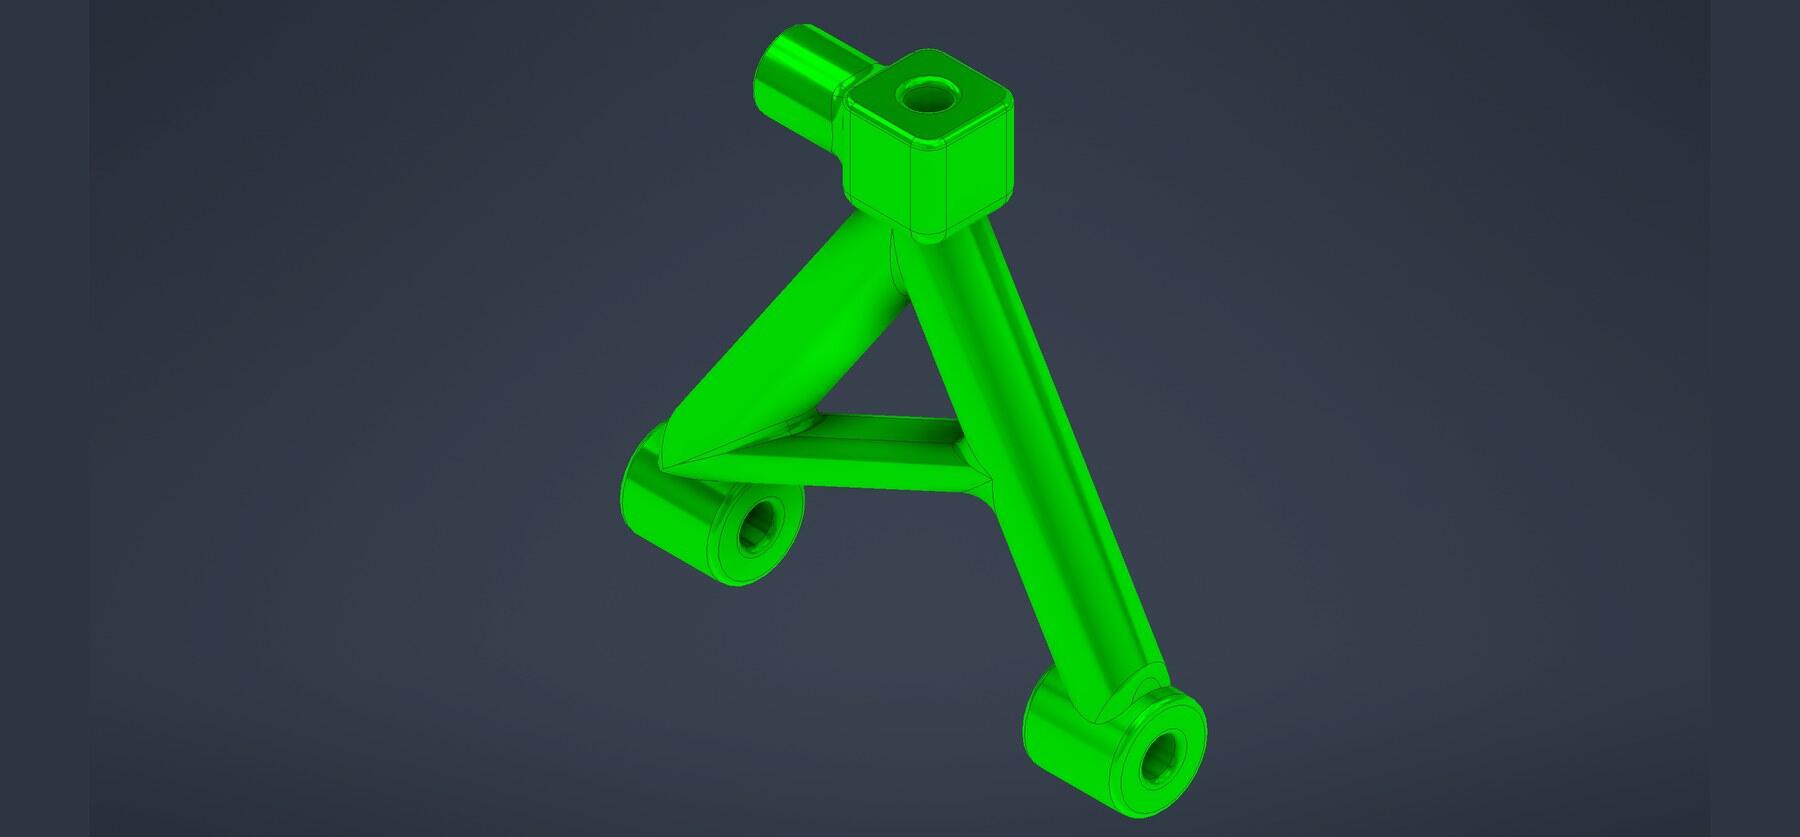
Designed the front lower control arm for a Formula SAE-style double wishbone suspension, balancing structural strength, manufacturability, and packaging.
Results
Modeled a tubular A-arm with inboard frame bushing mounts and an outboard spherical joint for the upright.
Designed for chromoly steel (AISI 4130) and fabrication by welding or tube bending.
Checked camber control, suspension travel clearance, and steering geometry compatibility.
Autonomous Robot Car | Mecanum 4WD
00.
PROJECT DETAILS
Role
Assembly, wiring, and programming
Timeline
2025
Tools
micro:bit, Microsoft MakeCode, ultrasonic and IR sensors
01.
OVERVIEW
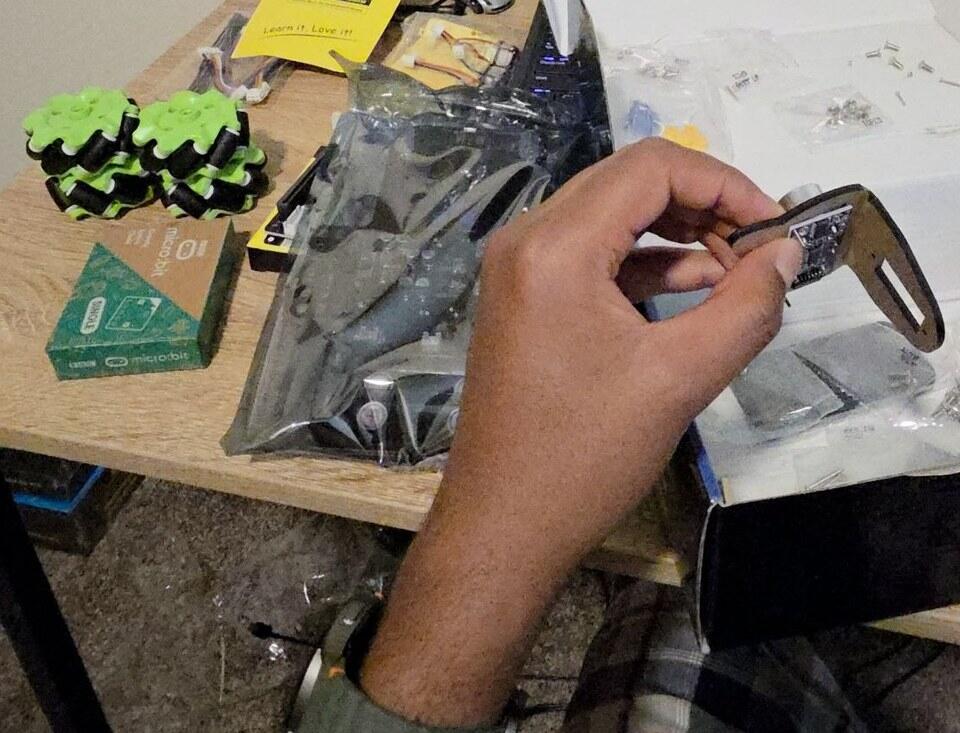
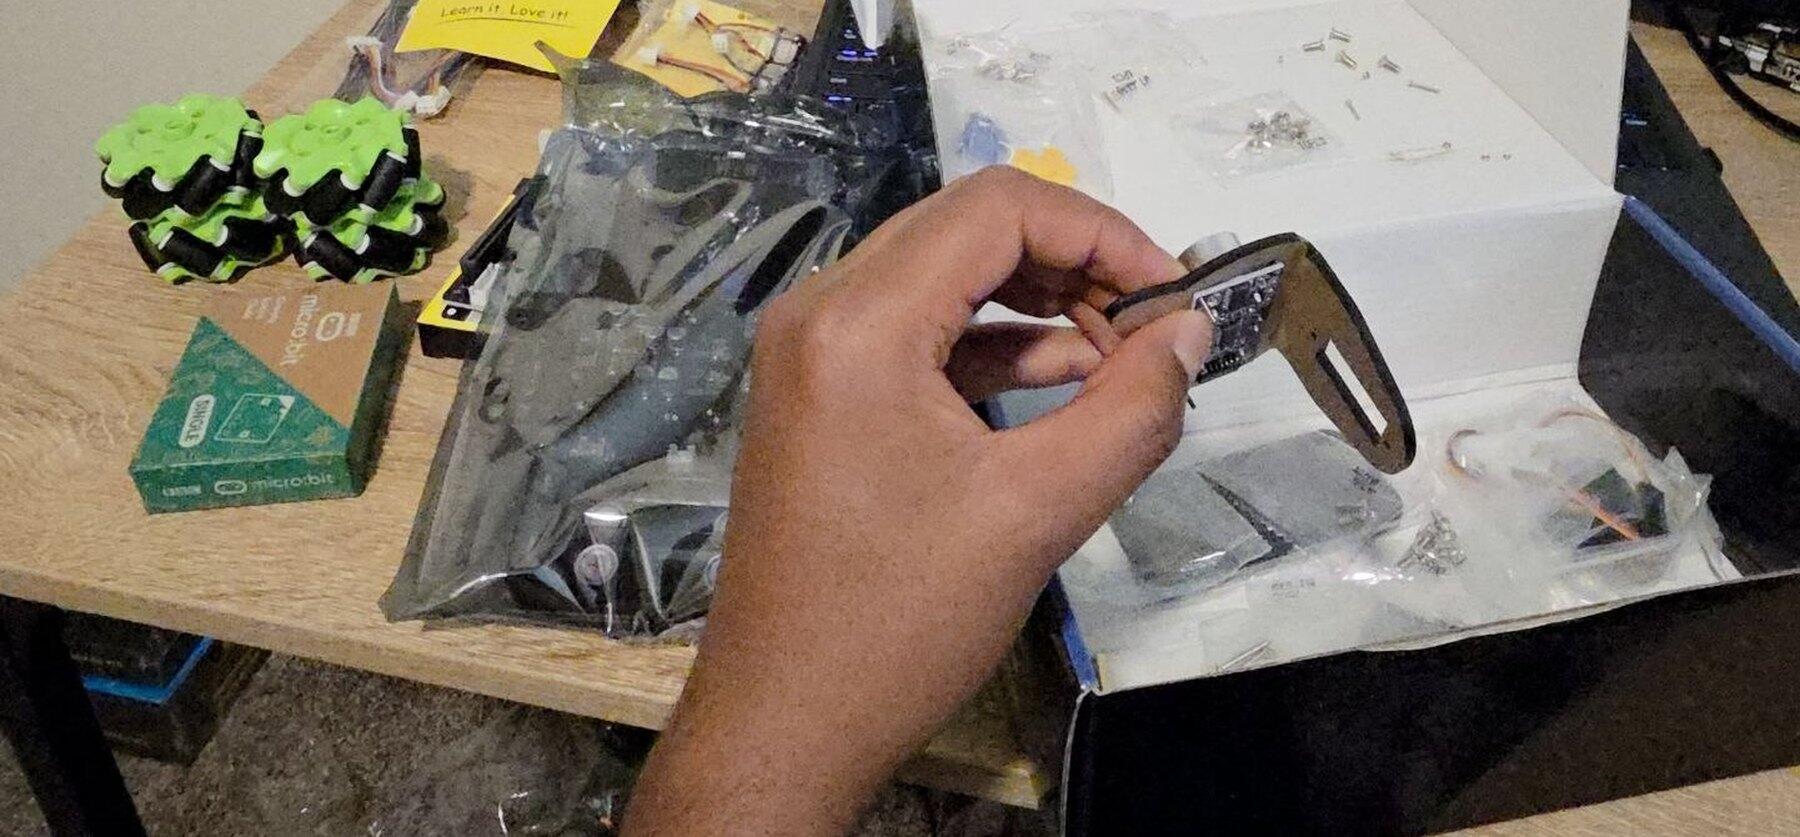
Built and programmed a four-wheel Mecanum robot car (Keyestudio KS4034F) that navigates on its own and avoids obstacles using real-time sensor feedback.
Results
Assembled the chassis, motors, Mecanum wheels, motor driver, and ultrasonic and IR sensors.
Programmed the control logic to detect obstacles, stop, turn, and continue in a new direction.
Tested in a bounded space with obstacles and tuned sensor position, turning logic, and motor coordination.
Gear Design | SolidWorks Modeling
00.
PROJECT DETAILS
Role
3D modeling
Timeline
2025
Tools
SolidWorks
01.
OVERVIEW
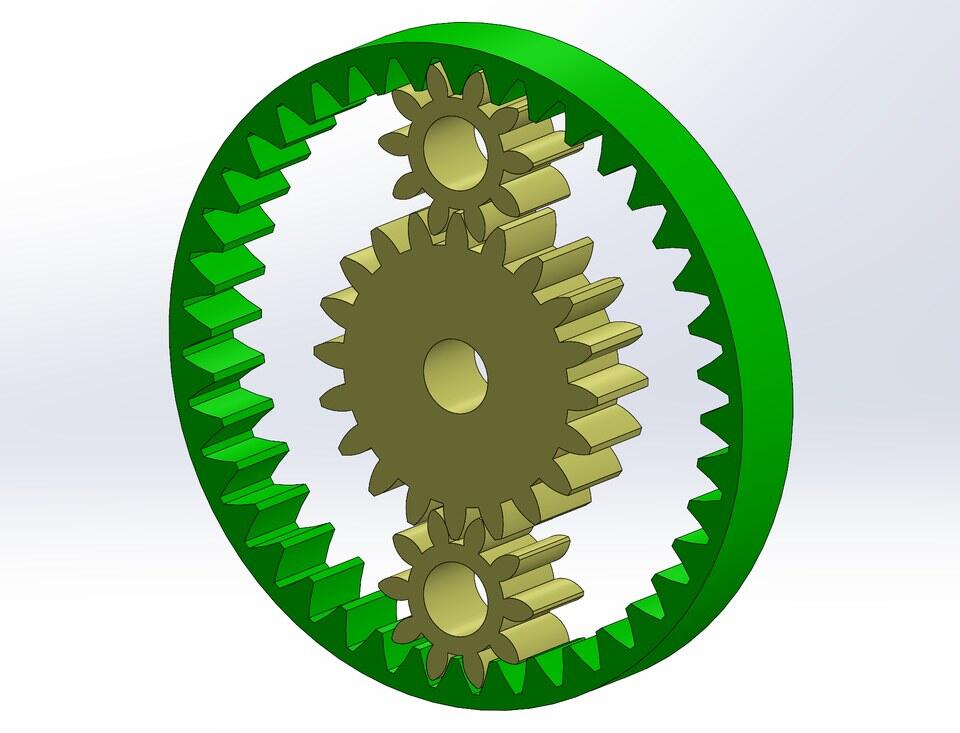
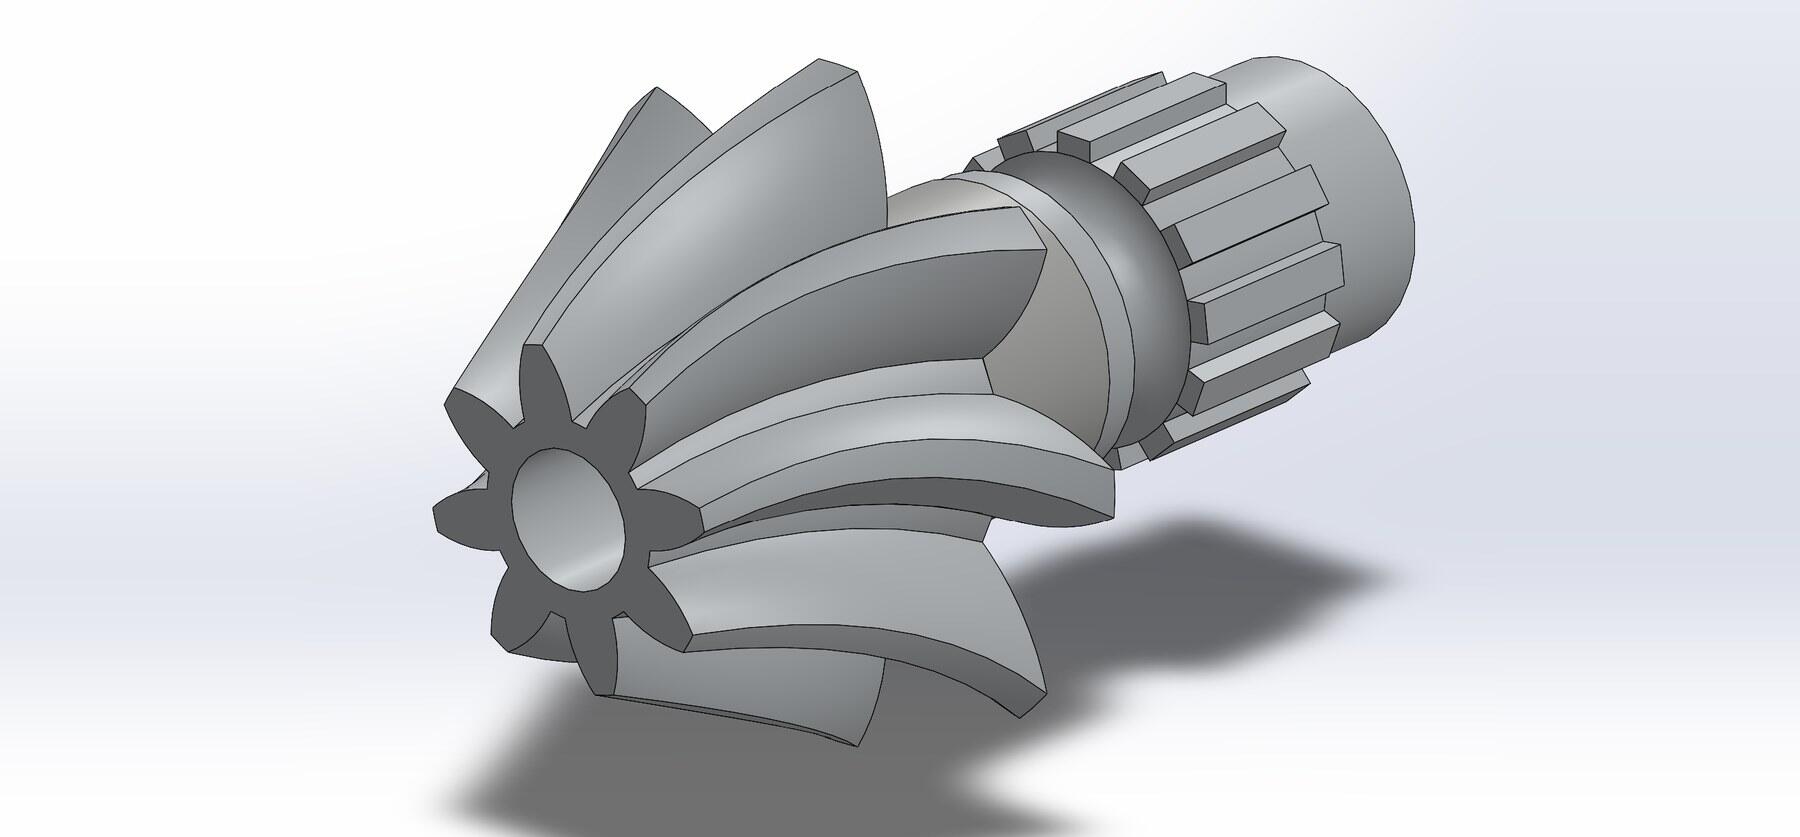
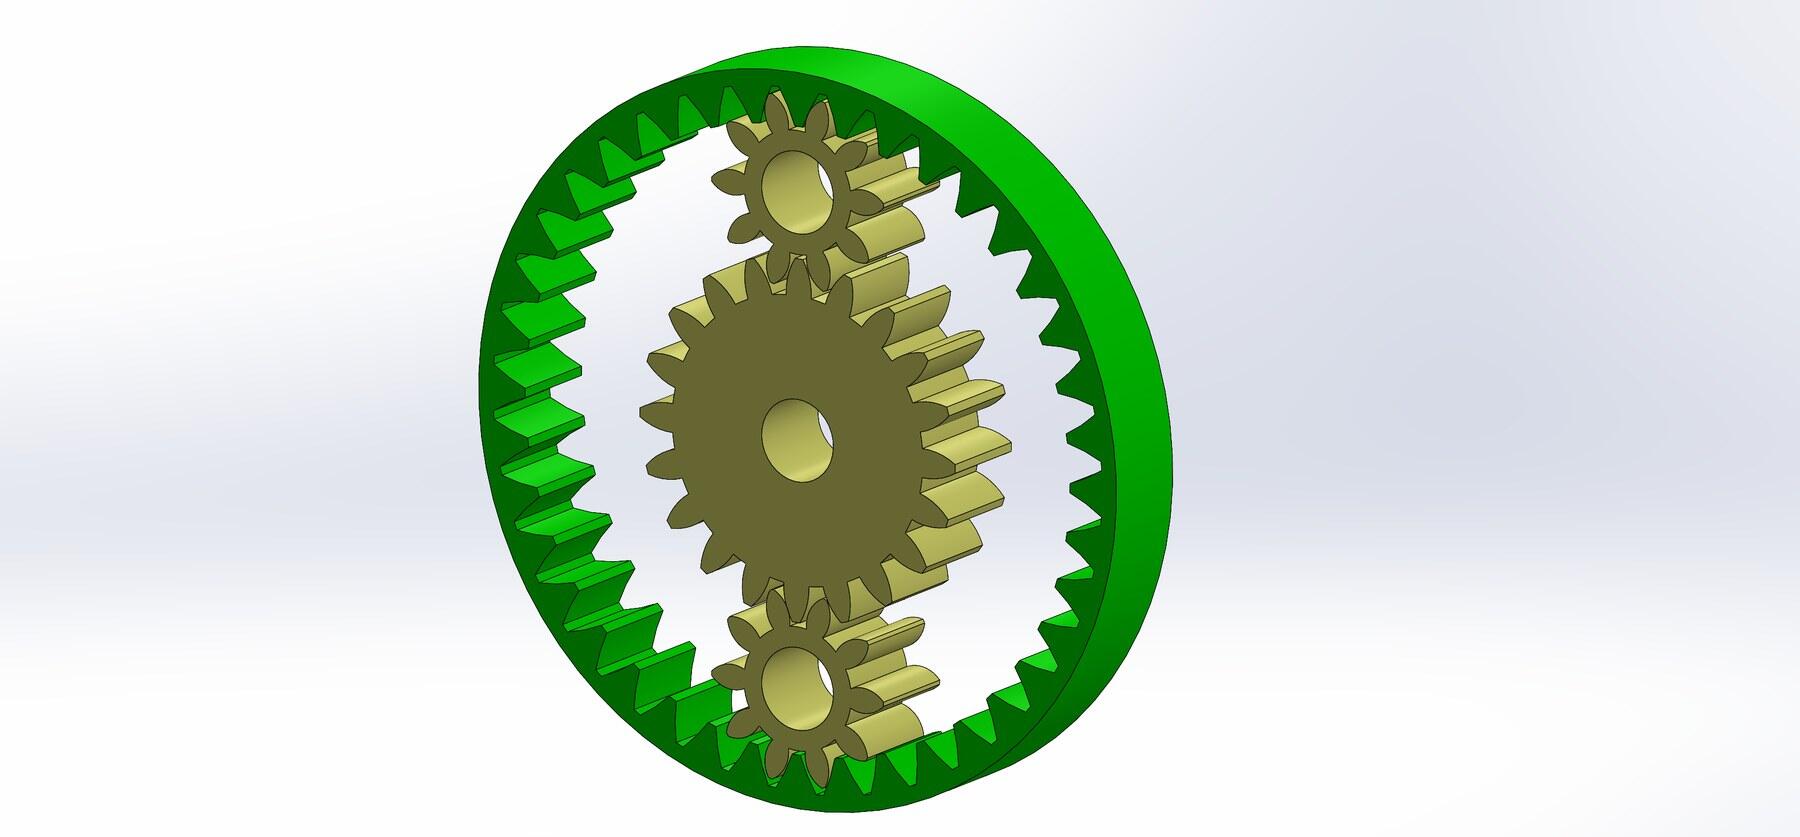
Modeled power transmission components in SolidWorks, including a pinion gear with a splined shaft and a complete planetary gear set.
Results
Modeled a pinion gear with a splined shaft for torque transfer.
Built a planetary gear assembly with sun, planet, and ring gears.
Created rendered views of the parts and the assembly.
Simulink Signal Modeling | MATLAB and Simulink
00.
PROJECT DETAILS
Role
Modeling and simulation
Timeline
2025
Tools
MATLAB, Simulink
01.
OVERVIEW
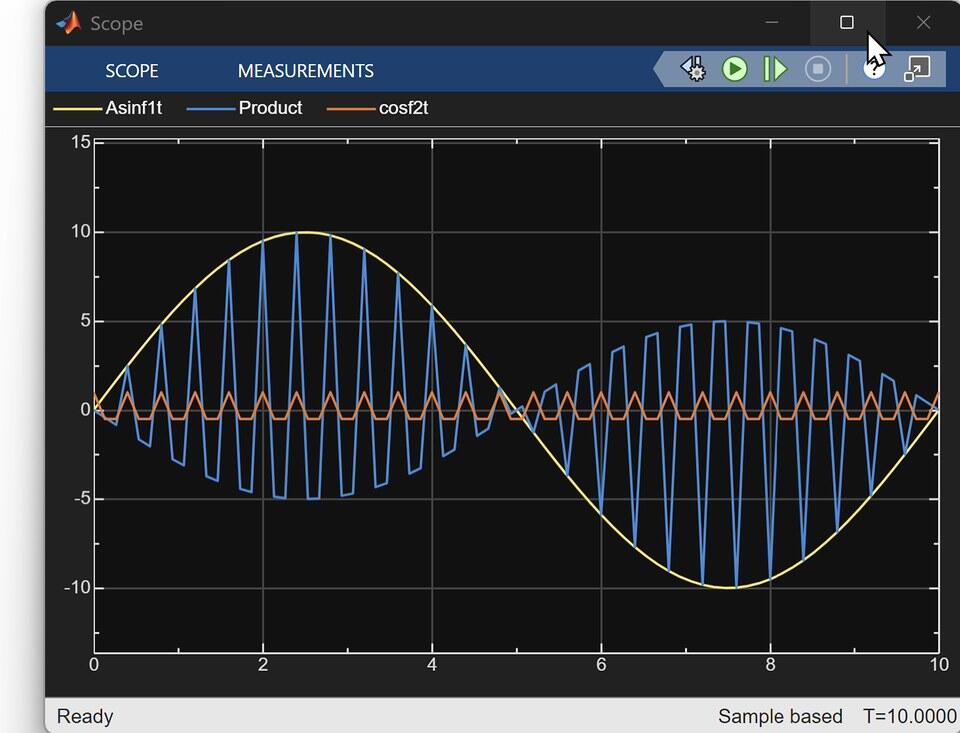
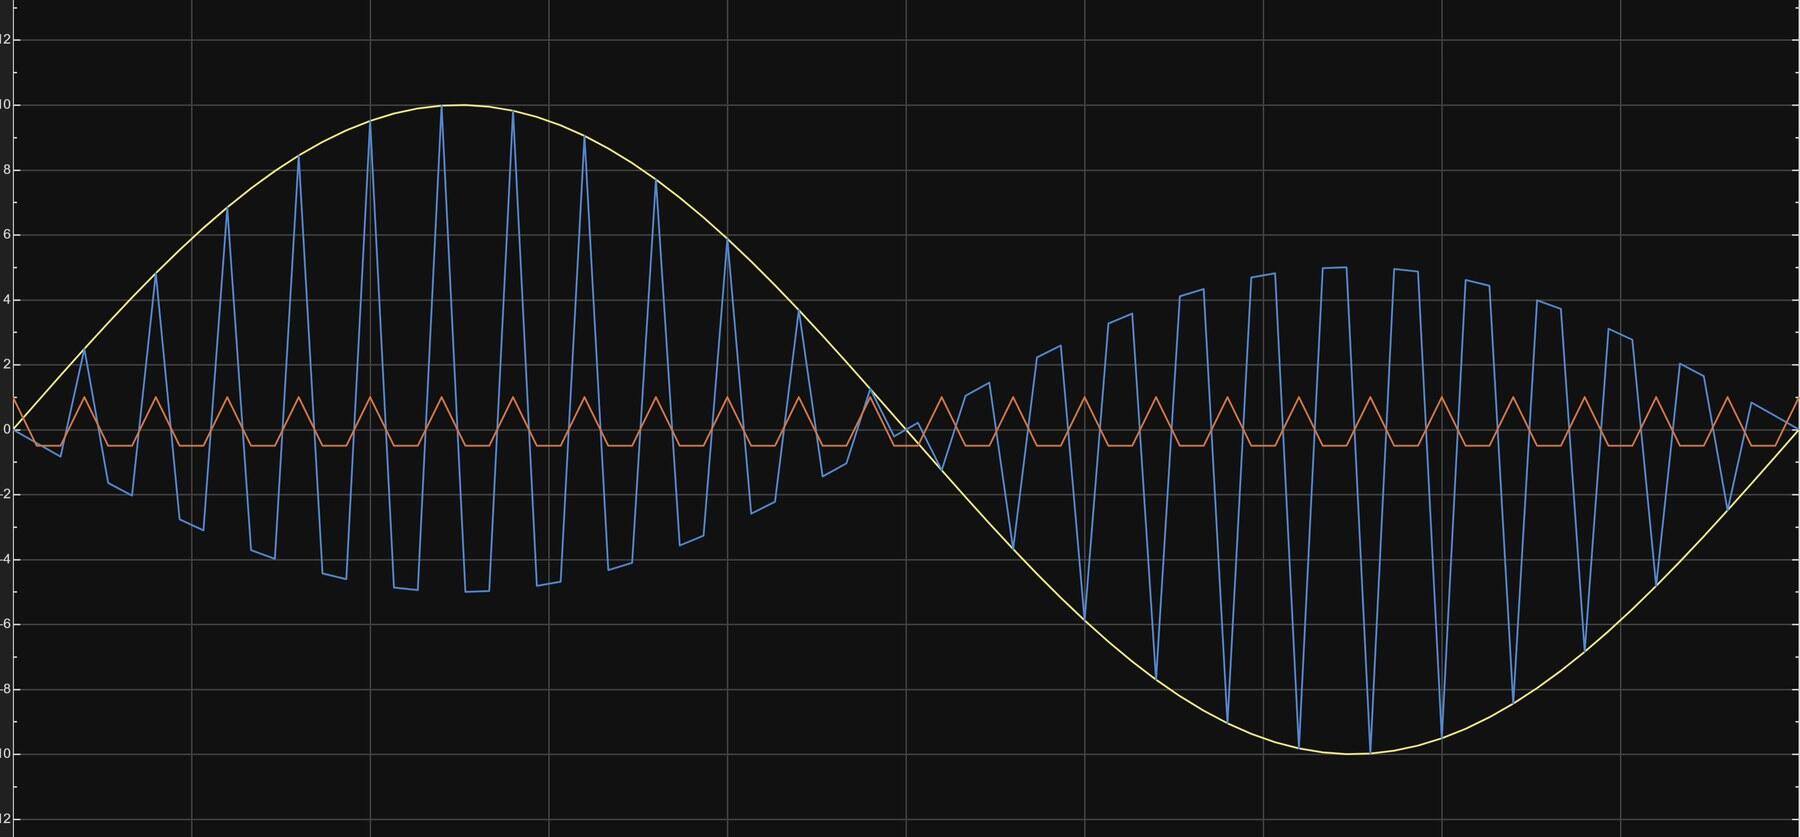
Built a Simulink model that generates a sine wave signal and displays it on a scope, as a foundation for larger dynamic and control system models.
Results
Set up the Sine Wave source block and its signal parameters.
Displayed and checked the output signal with a Scope block.